diff --git a/source/_posts/2023-04-22-josh-oap-part-1-4.md b/source/_posts/2023-04-22-josh-oap-part-1-4.md
index 8d294ad..a46c3b6 100644
--- a/source/_posts/2023-04-22-josh-oap-part-1-4.md
+++ b/source/_posts/2023-04-22-josh-oap-part-1-4.md
@@ -171,13 +171,15 @@ $$\begin{equation} \label{LeftHalfPowerPointInAngleDomain}
所以,对于 $0 \leqslant \theta \leqslant pi$,$\theta_\mathrm{L}, \theta_\mathrm{R} \geqslant 0$,在 $\theta$ 空间的半功率波束宽度为
-$$\begin{equation}
+$$\begin{equation} \label{HPBWOfUWLA}
\theta_\mathrm{H} = \theta_\mathrm{R} - \theta_\mathrm{L} = \cos^{-1} \left[ \cos\theta_\mathrm{T} - 0.450 \frac{\lambda}{Nd} \right] - \cos^{-1} \left[ \cos\theta_\mathrm{T} + 0.450 \frac{\lambda}{Nd} \right]
\end{equation}$$
除了当 $\theta_\mathrm{T} = 0$ 或 $\pi$(端射,endfire,信号入射方向与阵元排布方向平行)的情况,$\theta_\mathrm{L}$ 定义为最接近 $\theta = 0$ 的半功率点。当波束从正侧向($\theta_\mathrm{T} = \pi/2$)调向 $z$ 轴的正半轴(端射,$\theta_\mathrm{T} = 0$)时,波束变宽。在某点上,如式 $\eqref{LeftHalfPowerPointInAngleDomain}$
中所示,$\theta_\mathrm{L}$ 等于 0。在该点以外,在波束的那一边再没有半功率点。 Elliott[^1] 把这个点称为扫描极限(scan limit)。
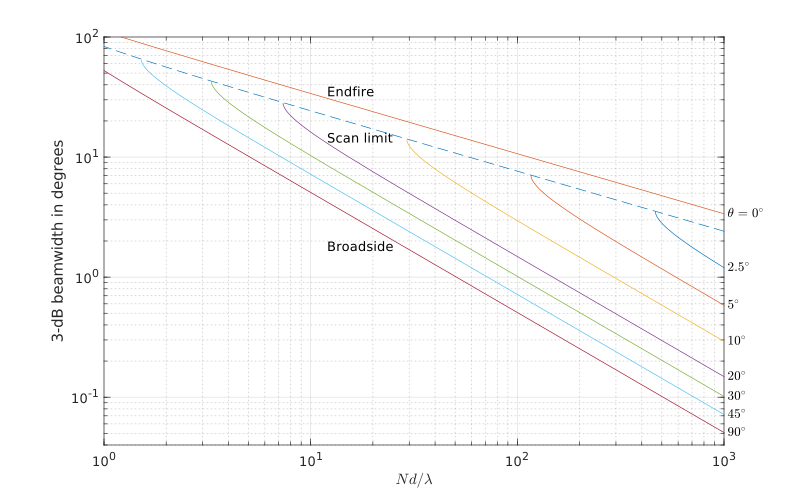
+ Elliot [^1] 画出了式 $\eqref{HPBWOfUWLA}$ 和式 $\eqref{HPBWOfEndfireUWLA}$ 中给出的波束宽度,并在[图 1-4-4](#fig.1-4-4) 中给出。
+
{width=1000px}
@@ -196,6 +198,45 @@ $$\begin{equation} \label{HPBWWithSmallAngle}
对于 $Nd \geqslant 5\lambda$,在正侧向附近,式 $\eqref{HPBWWithSmallAngle}$ 的误差在 0.2% 以内,在扫描极限附近,误差在 4% 以内。
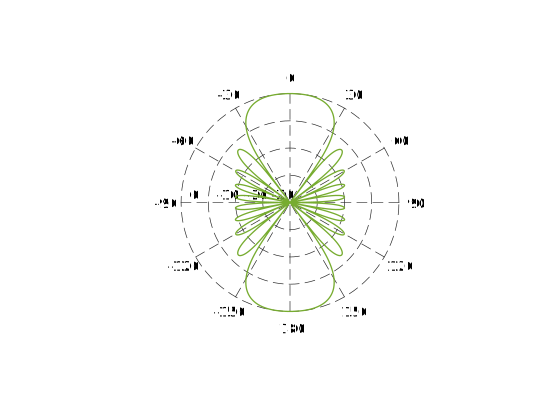
+ 当 $\theta_\mathrm{T} = 0$ 或 $\pi$ 时,最大响应轴的指向沿着阵列的轴线,此时称为一个端射阵列(endfire array)。一个标准 10 阵元端射阵列的波束方向图在[图 1-4-6](#fig.1-4-6) 中给出。在这种情况下,有
+
+$$\begin{equation} \label{HPBWOfEndfireUWLA}
+ \theta_\mathrm{H} = 2 cos^{-1} \left[ 1 - 0.450 \frac{\lambda}{Nd} \right], \quad \theta_\mathrm{T} = 0 \text{或} \pi
+\end{equation}$$
+
+
+
+{width=800px}
+
+可以把式 $\eqref{HPBWOfEndfireUWLA}$ 写成
+
+$$\begin{equation}
+ 1 - \cos \left( \frac{\theta_\mathrm{H}}{2} \right) = 0.450 \frac{\lambda}{Nd}
+\end{equation}$$
+
+或
+
+$$\begin{equation} \label{SineOfHPBWOfEndfireUWLA}
+ \sin \left( \frac{\theta_\mathrm{H}}{4} \right) = \sqrt{\frac{0.450}{2}\cdot \frac{\lambda}{Nd}}
+\end{equation}$$
+
+对于 $Nd \gg \lambda$,$\theta_\mathrm{H}$ 很小,则式 $\eqref{SineOfHPBWOfEndfireUWLA}$ 成为
+
+$$\begin{equation} \label{ApproximationOfHPBWOfEndfireUWLA}
+ \theta_\mathrm{H} = 2 \sqrt{0.890 \frac{\lambda}{Nd}}
+\end{equation}$$
+
+对于 $Nd \gg 5\lambda$,式 $\eqref{ApproximationOfHPBWOfEndfireUWLA}$ 的误差小于 1%。
+
+ 类似的,方向图的第一零点的位置为
+
+$$\begin{equation}
+ \theta_\mathrm{null} = \sqrt{2 \frac{\lambda}{Nd}}
+\end{equation}$$
+
+ 所以,一个线阵在端射位置的分辨率随 $Nd/\lambda$ 的平方根的倒数变化,而在正侧向的时
+候是线性的关系。
+
# 参考文献
1. Van Trees, Harry L. *Optimum array processing: Part IV of detection, estimation, and modulation theory.* John Wiley & Sons, 2002.